Every ARES sortie is supervised from a single interface that fuses position, telemetry and live camera views into one picture. The display below runs on simulated data from terrestrial testing — the same layout an operator would use to monitor a rover moving autonomously across an analogue field site, far from any joystick.
TELEMETRY
BATTERY
75.0 %
SOLAR INPUT
228.6 W
INT. TEMP
-6.1 °C
SPEED
0.1 m/s
HEADING
124.9 °
SLIP
4.8 %
BATTERY
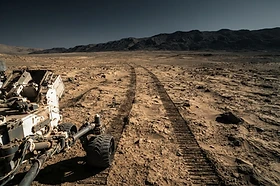
Interface shown with simulated data from terrestrial testing.
Autonomy does not mean absence. It means the human is free to think strategically while the machine handles the second-by-second work of staying alive on hostile ground. Mission Control is the thin layer between intent and execution — where an operator confirms a goal, and the rover works out the rest.