ORBITEXSPACE
02ARES Program

ARES-0

Autonomous Robotic
Exploration System

Status: In Development

Platform: Pioneer

ARES-0 is our first terrestrial autonomy testbed — a complete robotic platform for proving that a machine can perceive, decide and move on its own across terrain no human has mapped. Every subsystem on the Pioneer platform is designed to be pushed to failure on Earth before it is ever trusted with a mission that matters.

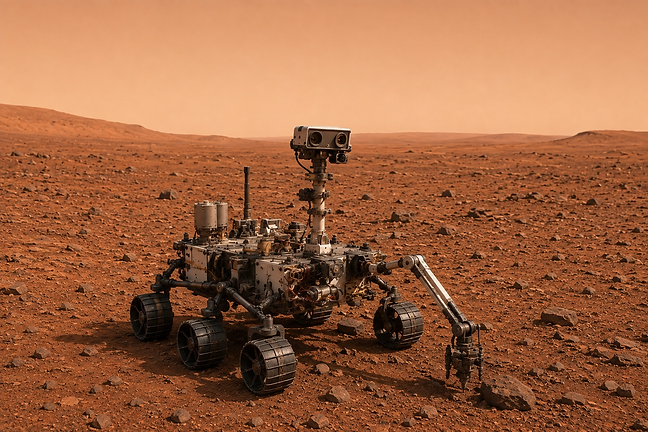
Pioneer — ARES-0 autonomous rover
REF / ARES-0 · PIONEER · REV 04
TAP A NODE
INTERACTIVE DIAGRAM — SELECT A HOTPOINT TO INSPECT SUBSYSTEM

Capabilities

A1Autonomous NavigationPath planning over unmapped terrain using onboard stereo vision, with no reliance on orbital oversight.
A2Terrain MappingReal-time local elevation models built from a single pass, accurate to centimeter scale.
A3Mission AutonomyGoal-directed operation — the rover is told what to achieve, not every wheel turn.
A4Modular PayloadsSwappable instrument and tool bays sized for science, construction or logistics missions.
Titanium rocker-bogie suspension joint

Fig. 02 — Rocker-bogie articulation, machined titanium

The Pioneer platform is not a flight article. It is the first honest answer to a hard question: can a machine be trusted to move, map and decide alone, for hours, across terrain that wants to stop it? When the answer is yes, the same software stack carries forward to the systems that will one day run on the Moon and Mars.

COOKIES

This site uses essential cookies to function and optional analytics to understand how it is used. We do not sell data. See our Cookie Policy for details.